🧐 About Me
I am an ELLIS PhD student in Computer Science at KTH Royal Institute of Technology, supervised by Prof. Danica Kragic and co-supervised by Prof. Marc Pollefeys at ETH Zürich. Before joining KTH, I completed my M.Sc. in Computer Science at ETH Zürich, where I conducted my Master’s thesis in the Computer Vision and Geometry Group (CVG), mentored by Boyang Sun and advised by Prof. Marc Pollefeys and Dr. Hermann Blum. Earlier, I received a Bachelor of Advanced Computing (Honours) from The University of Sydney under the supervision of Prof. Athman Bouguettaya. My research interests broadly lie in computer vision and embodied AI, with a focus on learning generalizable robot policies from human videos for dexterous manipulation and developing robot foundation models, including vision-language-action (VLA) and World Action Models (WAMs).
🔥 News
- 2026.09: 🎉🎉 Our paper LIME has been accepted to CoRL 2026.
- 2025.08: 🎉🎉 Our paper ActLoc is accepted to CoRL 2025.
- 2025.03: 🎉🎉 Our paper EgoGaussian is accepted to 3DV 2025.
📝 Selected Publications
(* indicates equal contribution)
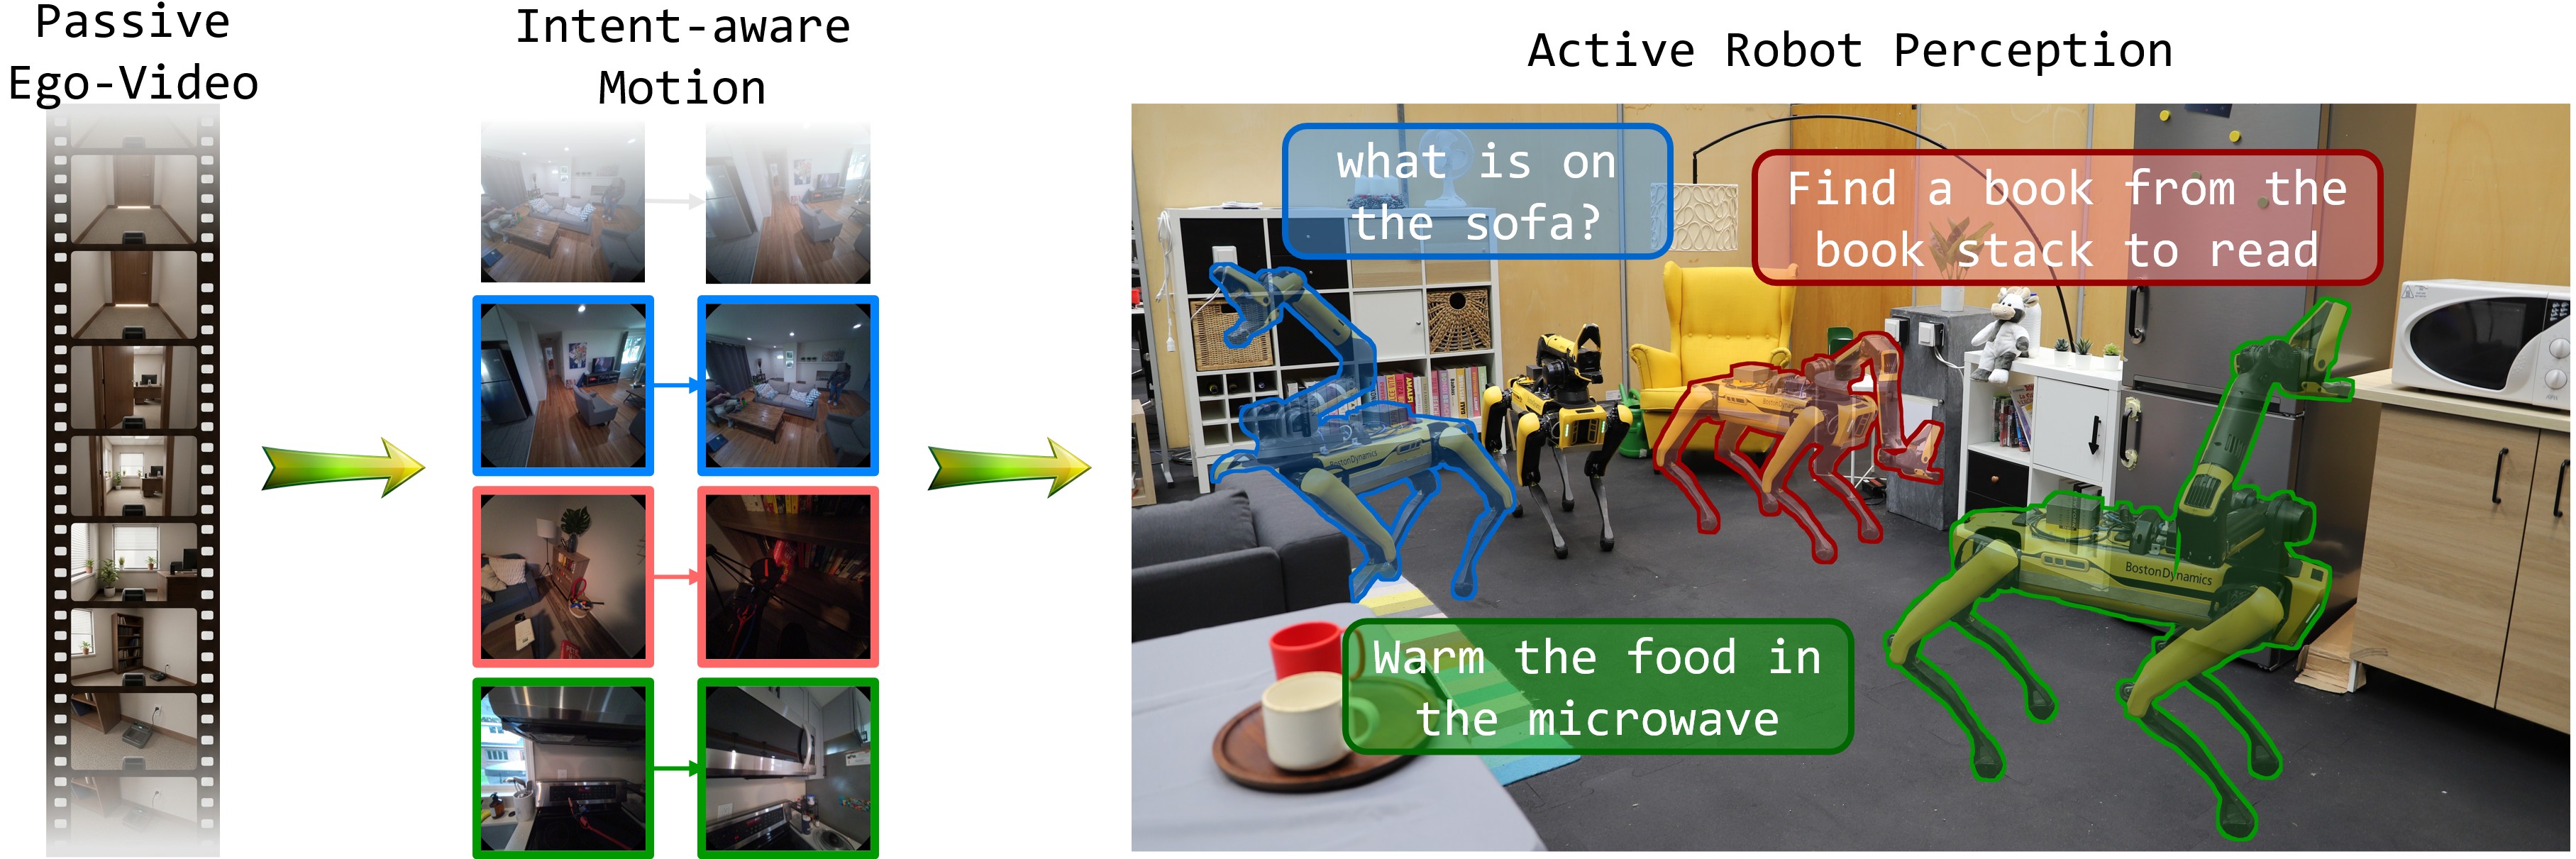
LIME: Learning Intent-aware Camera Motion from Egocentric Video
[Conference on Robot Learning (CoRL) 2026]
Boyang Sun*, Jiajie Li*, Yung-Hsu Yang, Chenyangguang Zhang, Tim Engelbracht, Sunghwan Hong, Cesar Cadena, Marc Pollefeys, Hermann Blum
TL;DR: LIME learns from passive egocentric video to predict intent-conditioned target camera poses, enabling robots to acquire task-relevant visual evidence for active perception and downstream tasks.

ActLoc: Learning to Localize on the Move via Active Viewpoint Selection
[Conference on Robot Learning (CoRL) 2025]
Jiajie Li*, Boyang Sun*, Luca Di Giammarino, Hermann Blum, Marc Pollefeys
[Project Page] [Paper] [Code] [Demo]
TL;DR: ActLoc learns from SfM maps to predict, at each waypoint, a distribution of localization accuracy over multiple yaw–pitch angles (a LocMap), then uses it in planning to pick camera orientations that improve localization reliability under motion constraints, with real-time inference.

EgoGaussian: Dynamic Scene Understanding from Egocentric Video with 3D Gaussian Splatting
[International Conference on 3D Vision (3DV) 2025]
Daiwei Zhang, Gengyan Li, Jiajie Li, Mickaël Bressieux, Otmar Hilliges, Marc Pollefeys, Luc Van Gool, Xi Wang
TL;DR: From a single egocentric RGB video, EgoGaussian jointly reconstructs the static scene and tracks rigid objects by representing them with explicit 3D Gaussian sets and optimizing per-frame object poses, yielding high-quality novel view synthesis without depth sensors or object models.
🧑🏫 Teaching
- 2026, Spring Semester, Teaching Assistant, Mobile GIS and Location-Based Services (103-0247-00L), ETH Zürich
- 2022, Semester 2, Academic Tutor, Computing 1B: OS and Network Platforms (INFO1112), The University of Sydney
- 2021, Semester 1, Academic Tutor, Introduction to Programming (INFO1110), The University of Sydney
🤝 Academic Service
- 2026, Reviewer, Conference on Robot Learning (CoRL)
- 2025, Reviewer, IROS Workshop on Active Perception
📖 Education
- 2026 - present, Ph.D. in Computer Science, School of Electrical Engineering and Computer Science, KTH Royal Institute of Technology, Stockholm, Sweden (ELLIS PhD Program)
- 2023 - 2026, M.Sc. in Computer Science, Department of Computer Science, ETH Zürich, Zürich, Switzerland
- 2019 - 2023, Bachelor of Advanced Computing (Honours), School of Computer Science, The University of Sydney, Sydney, Australia